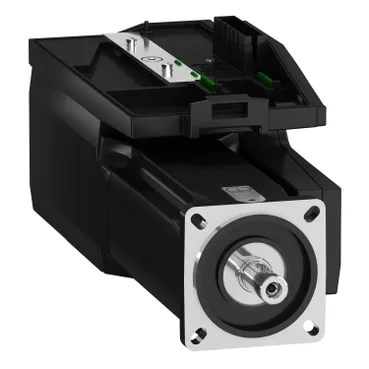
The Schneider Electric BMI0702P27F is a three-phase servomotor from the BMI series, built for closed-loop position control with an integrated holding brake, absolute multiturn SinCos Hiperface feedback, and an EMC filter already in the housing. It ships as a single unit with natural convection cooling, rated IP65 for dust and water-jet protection.
Performance by supply voltage
This motor delivers different torque and speed depending on the line voltage feeding the drive. At 208 V three-phase it produces 21.2 lbf.in (2.4 N.m) nominal torque with a nominal speed of 1800 rpm and 400 W output. On 400 V the torque drops slightly to 19.5 lbf.in (2.2 N.m) while speed rises to 3600 rpm and output reaches 800 W. At 480 V nominal torque is 17.7 lbf.in (2 N.m) with 4400 rpm and 900 W output. Peak stall torque holds at 60.2 lbf.in (6.8 N.m) across all three voltages, and the maximum continuous current is 9.6 A Irms. The supply frequency range is 50/60 Hz ±5 %.
Feedback, brake, and environmental ratings
The absolute multiturn SinCos Hiperface feedback provides position information at zero speed — no homing routine needed after power loss. The holding brake exerts 26.6 lbf.in (3 N.m) holding torque and draws 5 W pull-in power. The motor is sized for a 70 mm international standard flange (2.8 in) with a centring collar depth of 2.5 mm. It accepts axial forces up to 20 % of the rated radial force; the radial force limit varies from 710 N at 1000 rpm down to 390 N at 6000 rpm. The stator resistance is 8.89 Ω and inductance is 25.75 mH at 20 °C. The back EMF constant is 77.18 V/krpm, and the torque constant is 1.15 N.m/A.