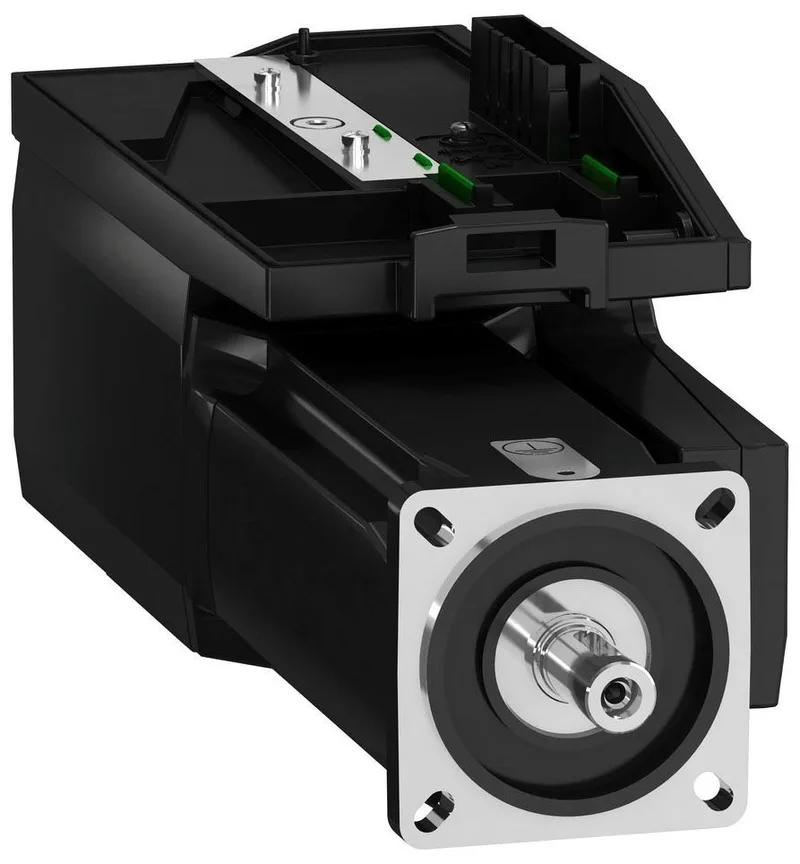
Schneider Electric BMI0702P37A

Schneider BMI0702P37A Lexium 32i servo motor, 10 poles, 8000 rpm

MPNBMI0702P37A
Active

Schneider Electric Lexium 32i BMI0702P37A servo motor, 10 poles, 8000 rpm max, 2.48 Nm torque, 400-900 W depending on supply, IP65, absolute multiturn SinCos Hiperface encoder, keyed shaft, no brake.

$2,440.00Ref. price · indicative, final on quote
Source DocumentedChannel stated on listing & quote
Condition PhotosReal unit photos / video on request
WhatsApp AnswersFast human replies for machine-down parts
Worldwide DispatchDHL/FedEx — transit quoted per order
Independent China distributor & sourcing agent· Listing updated Sep 2026

Specifications

BMI0702P37A key specifications
ParameterValue
Feedback typeAbsolute multiturn SinCos Hiperface
Type of coolingNatural convection
Product or component typeServo motor with power stage
Supply voltage limits208...480 V
Supply voltage208...480 V - 15...10 %
Maximum current irms9.6 A 208 V, three phase 9.6 A 400 V, three phase 9.6 A 480 V, three phase
Output current 3s peak6 A 400 V 3 s
Continuous stall current2 A
Continuous output current2 A 8 kHz
Nominal output power400 W 208 V three phase 800 W 400 V three phase 900 W 480 V three phase
Supply frequency50/60 Hz - 5...5 %
Network frequency limits47.5...63 Hz

All specifications

BMI0702P37A additional specifications
ParameterValue
Number of motor poles10
PhasesThree phase
IP degree of protectionIP65
Mounting supportInternational standard flange
Mounting holes diameter0.2 in (5.5 mm)
Number of mounting holes4
Circle diameter of the mounting holes3.0...3.2 in (75...82 mm)
Electrical connectionPrinted circuit board connector
EMC filterIntegrated
Key width0.2 in (4 mm)
Centring collar depth0.10 in (2.5 mm)
Length10.6 in (268 mm)
CategoryUS1PC5618287
Shaft endKeyed
Second shaftWithout second shaft end
Shaft length0.9 in (23 mm)
Holding brakeWithout
Nominal speed1800 rpm 208 V three phase 3600 rpm 400 V three phase 4400 rpm 480 V three phase
Rotor inertia1.13 kg.cm²
Nominal torque21.2 lbf.in (2.4 N.m) 208 V three phase 19.5 lbf.in (2.2 N.m) 400 V three phase 17.7 lbf.in (2 N.m) 480 V three phase
Shaft diameter0.4 in (11 mm)
Torque constant1.15 N.m/A 68 °F (20 °C)
Back emf constant77.18 V/krpm 68 °F (20 °C)
Device short nameBMI
Motor flange size2.8 in (70 mm)
Peak stall torque60.2 lbf.in (6.8 N.m) 208 V three phase 60.2 lbf.in (6.8 N.m) 400 V three phase 60.2 lbf.in (6.8 N.m) 480 V three phase
Stator inductance25.75 mH 68 °F (20 °C)
Stator resistance8.89 Ohm 68 °F (20 °C)
Maximum axial force fa0.2 x Fr
Number of motor stacks2
Continuous stall torque21.95 lbf.in (2.48 N.m) 208...480 V three phase
Maximum radial force fr710 N 1000 rpm 560 N 2000 rpm 490 N 3000 rpm 450 N 4000 rpm 410 N 5000 rpm 390 N 6000 rpm
Centring collar diameter2.4 in (60 mm)
Maximum mechanical speed8000 rpm
Speed feedback resolution32768 points/turn x 4096 turns
Distance shaft shoulder-flange0.10 in (2.5 mm)
Stator electrical time constant2.9 ms 68 °F (20 °C)

Product details

Overview

The BMI0702P37A is a Schneider Lexium 32i servo motor with a 10-pole rotor, rated for 2.48 Nm continuous torque and a top speed of 8000 rpm. Power output depends on the supply: 400 W at 208 V three-phase, 800 W at 400 V, and 900 W at 480 V. It carries an absolute multiturn SinCos Hiperface encoder resolving 32768 points per turn over 4096 turns, so the drive knows the shaft position on power-up without a homing move. Sealed to IP65 with a keyed shaft and no holding brake, it is built for direct integration into the Lexium 32i drive family via a printed circuit board connector.

The 10-pole construction sets the BMI0702P37A apart from the 5-pole BMH1401P17F2A; the higher pole count reduces torque ripple and improves low-speed smoothness, making it a better fit for direct-drive or high-accuracy indexing applications where cogging must be minimized.

MPN
BMI0702P37A