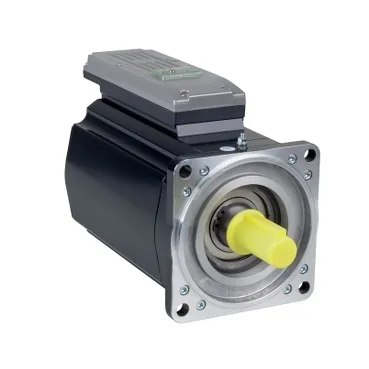
PacDrive 3 ILM, 140 mm flange with integrated drive
The ILM1402P21A0000 is a Schneider Electric ILM-series servo motor with integrated drive, member of the PacDrive 3 range, built on a 140 mm international-standard flange with a 309 mm body length and a single untapped 24 mm shaft. Natural-convection cooling, no holding brake, and IP65 sealing mark this out as a cabinet-friendly integrated axis — the drive electronics ride on the motor back, so a single cable run replaces the traditional servo amplifier enclosure.
Torque class and current draw for axis sizing
Nominal torque is 9.1 N.m at a nominal speed of 2000 rpm, with continuous stall torque rated at 12.5 N.m; peak stall torque reaches 55 N.m, the figure that decides whether the axis can absorb a step shock without saturating the current loop. Line-rated current is 3.7 A with a continuous stall current of 4.8 A, and the inverter section supports a maximum Irms of 24 A — the headroom above nominal is what lets the drive deliver the 55 N.m peak without tripping. Nominal mechanical output power is 1910 W at the rated point; the back-EMF constant of 173 V/krpm at 20 °C is the figure to check against the DC-bus voltage when the axis is back-driven or run at field-weakening speeds.
Feedback, stator and rotor — what the drive expects
Position feedback is an absolute single-turn SinCos Hiperface encoder with 128 sine periods, which the PacDrive controller resolves to single-turn absolute position without a battery-backed multi-turn module. Stator resistance is 1.9 Ω phase-to-phase at 20 °C, dropping to 1.32 Ω phase-to-neutral at 120 °C, and stator inductance shifts from 22 mH at 20 °C to 11 mH at 120 °C — those numbers are what the auto-tune loop locks onto during commissioning, so they govern current-loop bandwidth rather than nameplate torque.
Mechanical loads, mounting and thermal envelope
Maximum radial force on the shaft is 2430 N at 1000 rpm, falling to 1930 N at 2000 rpm, with axial load capped at 0.2 × Fr — the standard belt or pinion sizing math applies directly because the derating curve is a function of speed, not just a single number. Mounting is via four 11 mm holes on the 140 mm flange with a 130 mm centring collar 3.5 mm deep, matching the IEC standard flange footprint that bolts to most right-angle gearheads and planetary reducers on the PacDrive motion platform. Natural-convection cooling on an IP65 housing means the motor cannot be force-cooled; in a sealed cabinet the ambient around the back of the drive has to stay within the manufacturer's thermal envelope, or the continuous torque derates from the 12.5 N.m stall figure.