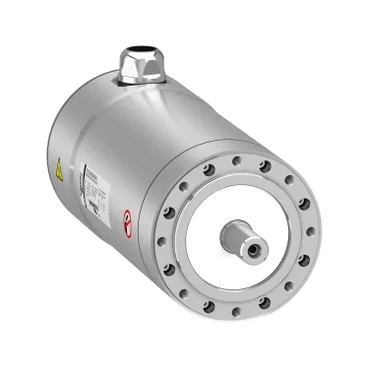
Motor specs that drive the selection
The FCE200523B200 is a Schneider SHS servo motor rated for 1260 W continuous output at 4000 rpm nominal speed, with a nominal torque of 3 Nm and a peak stall torque of 28.3 Nm — that peak figure is what gets a load through a sticky spot without tripping the drive. It ships with an absolute multiturn SinCos Hiperface encoder — single-cable feedback that carries position and temperature data back to the drive, no separate encoder cable needed. IP69K on the motor body means it survives high-pressure, high-temperature washdown — a food-processing or pharmaceutical line fit. IP67 on the motor means the cable entry and bearing seal are protected against temporary immersion.
Mounting and shaft interface
Flange size is 100 mm (3.9 in), centring collar depth 3.5 mm. The smooth shaft is 19 mm diameter, 40 mm long with a 6 mm keyway — standard NEMA or IEC metric interface, no custom adapter needed. Electrical connection is a cable with stripped ends, 270.7 mm long. That's a fixed pigtail — plan the cable routing to the drive within that length, or budget a junction box. Maximum radial force at the shaft is 660 N at 4000 rpm, maximum axial force 160 N. If the load applies a belt tension or overhung load above those numbers, the bearing life drops fast.
Electrical and thermal limits
Stator resistance is 1.4 Ω, inductance 8.8 mH, back EMF constant 2.1 V/krpm at 20 °C. The torque constant is 1.18 Nm/A — so the drive's current loop directly sets the torque output, no conversion factor needed. Peak current is 28.3 A for 3 seconds — that's the I²t limit for the winding temperature. Continuous current at stall is 6.75 Nm, 3 Nm at rated speed. The hot-spot copper temperature is 130 °C; the natural-convection cooling relies on the motor surface being clear of debris. Switching frequency is 8 kHz — standard for a servo drive PWM stage. The motor is a 4-pole, 3-stack design, so it's a medium-inertia rotor tuned for dynamic response rather than ultra-low cogging.