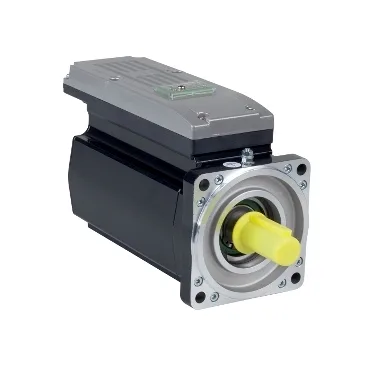
PacDrive 3 ILM integrated-drive servo, 100 mm flange
The Schneider Electric ILM1003P22A0000 is a servo motor with integrated drive from the PacDrive 3 family — a one-cable brushless servo that pairs a Hiperface SinCos absolute multiturn feedback encoder with the drive electronics inside the motor housing, so the cabinet side only needs a power feed and a fieldbus drop rather than a separate drive module. The ILM short name and the 100 mm flange size place it in the mid-format of the PacDrive 3 line, sized for packaging machines, indexing tables and small gantry axes where panel space is at a premium. Continuous ratings are 3.5 N·m nominal torque at 2.4 A line current, with a continuous stall torque of 5.8 N·m at 3.6 A; peak stall reaches 28.3 N·m and peak line current 21.2 A for short acceleration windows. Nominal output power is 1100 W at the 3000 rpm nominal speed — the figure that fixes the motor's continuous working envelope against the drive's S-curve accel budget.
Torque, current, and thermal headroom
The torque constant of 1.61 N·m/A at 120 °C winding temperature is the conversion factor the drive uses to translate a current command into shaft torque — hot windings deliver slightly less torque per amp than cold ones, so the drive's i²t model must use the 120 °C figure rather than a 25 °C value. Continuous stall torque of 5.8 N·m at 3.6 A sits well below the 28.3 N·m peak, giving roughly 4.9× peak-to-continuous headroom for accel/decel pulses without tripping the i²t foldback. Stator resistance climbs from 1.81 Ω phase-to-neutral at 120 °C to 2.6 Ω phase-to-phase at 20 °C, and stator inductance drops from 15.6 mH at 20 °C to 7.8 mH at 120 °C — the inductance swing is what sets the drive's current-loop bandwidth across the operating temperature range. With natural-convection cooling (no fan) and IP65 sealing, the motor relies entirely on its flange-to-machine thermal path to dump losses from the 1100 W continuous output.
Encoder and motor stack
Feedback is an absolute multiturn SinCos Hiperface encoder with 128 periods of SinCos resolution per turn — that resolution is what governs the low-speed torque smoothness and the absolute position retention after a power cycle, so the controller does not need a homing routine on every restart. The 8-pole rotor and 3-stack stator are the electromagnetic building blocks that produce the 3000 rpm nominal speed and the back-EMF constant of 103 V/krpm at 20 °C — the latter is the value the drive uses to set the field-weakening entry point if the application ever asks for speeds above nominal.
Mechanical footprint and shaft loading
Body length is 285 mm with a 30 mm key width and a 100 mm international-standard flange; the 19 mm untapped shaft runs 40 mm long and accepts a separate key and coupling or pulley. Centring collar is 95 mm diameter by 3.5 mm deep, with four 9 mm mounting holes — a standard IEC-style bolt pattern that drops onto most NEMA-adapter or machine-side sub-plates without an adapter plate. Maximum radial load on the shaft is 1050 N at 1000 rpm, falling to 830 N at 2000 rpm and 730 N at 3000 rpm — the de-rating reflects bearing life at higher rpm and is the number to check against belt tension or coupling misalignment on the driven side. Maximum axial force Fa is constrained to 0.2 × Fr, so a straight-in-line coupling with minimal end thrust is the safest installation; a helical-bevel gear box with significant axial load will need a separate thrust bearing.
Sealing and duty environment
IP65 with natural-convection cooling means the ILM1003P22A0000 is sealed against low-pressure water jets and dust ingress — suitable for food-and-beverage washdown zones, machine-tool coolant splash, and outdoor cabinets where the housing is hosed down during shift change. Natural convection also means no fan to fail or filter to clean, which is the trade-off for the 1100 W continuous ceiling: the motor cannot be installed in a fully enclosed, unventilated pocket where its own losses cannot radiate through the flange.
Sourcing posture
Buyers matching this code against a PacDrive 3 line should verify the Hiperface feedback option, the absent holding brake, and the untapped 19 mm shaft against the BOM line before committing the position.