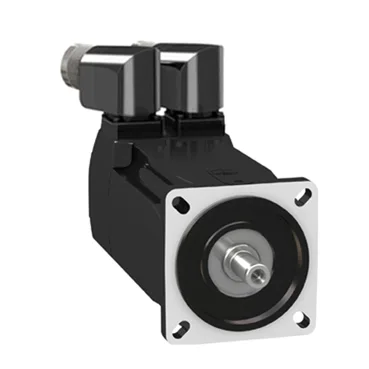
The MH30702P02F2200 delivers 1380 W continuous power at 5500 rpm nominal speed, with a nominal torque of 2.37 N.m (20.98 lbf.in) when paired with an LXM52 or LXM62 drive at 115 V three-phase supply — the torque curve shifts slightly at higher line voltages: 2.23 N.m at 230 V single-phase, 2.01 N.m at 400 V three-phase, and 1.89 N.m at 480 V three-phase. Peak stall torque reaches 7.4 N.m (65.5 lbf.in) across the 115–480 V three-phase range, and the maximum current Irms is 9.65 A — this gives the servo headroom for acceleration transients without saturating the drive.
Built-in holding brake and encoder feedback
The motor includes a holding brake with 3 N.m (26.6 lbf.in) holding torque and 7 W pull-in power — enough to hold a vertical axis load at standstill without servo power, and the low power draw keeps the thermal budget tight in the junction box. Feedback comes from a multiturn SinCos Hiperface encoder — a single-cable absolute position protocol that eliminates a separate encoder cable and reduces wiring complexity on the moving axis. The encoder type and the rotatable right-angled connectors simplify cable routing in tight cabinet layouts; the IP65 rating means the motor body withstands washdown and dust ingress without an additional enclosure.
Mechanical interface and mounting
The motor uses an international standard flange with a 70 mm (2.8 in) flange size and a 60 mm centring collar diameter — mounts directly to standard servo gearboxes and linear actuators without an adapter plate. Shaft is smooth, 11 mm diameter, 23 mm long; the centring collar depth is 2.5 mm. Maximum radial force at the shaft nose is 710 N at 1000 rpm, derating to 390 N at 6000 rpm — relevant for belt-drive or overhung load applications where bearing life depends on radial load.