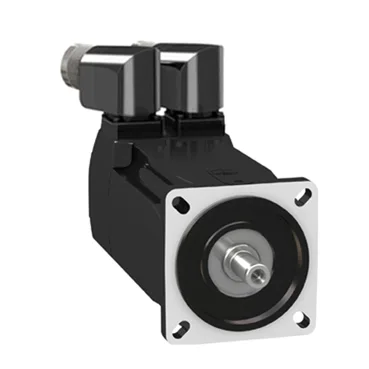
The MH30702P17F2200: The holding brake delivers 3 N.m static torque — enough to hold a vertical-axis load at standstill without the drive having to maintain a holding current. Brake pull-in power is only 7 W, so the thermal load on the motor end-bell stays modest even with frequent engage/release cycles. Torque output depends on which LXM5x or LXM6x drive supplies it: at 115 V three-phase you get the full 2.37 N.m; at 480 V three-phase it derates to 1.89 N.m. The peak stall torque is 7.4 N.m across the voltage range — useful for acceleration transients or breaking away a stuck load.
Encoder, feedback, and position-hold for safety circuits
The multiturn SinCos Hiperface encoder gives absolute position over multiple shaft revolutions — no homing sequence needed after a power cycle. This matters for applications where the axis must resume from the last known position after an E-stop or unplanned shutdown. IP65 rating on the motor body and the rotatable right-angled connectors means the assembly withstands washdown and airborne particulates. The connector rotates to orient the cable exit — useful when the motor mounts in a tight enclosure corner and the cable needs to route without a tight bend radius.
Mounting interface and mechanical limits
The 70 mm IEC flange (2.8 in) with a 0.2 in (5.5 mm) mounting hole pattern and 0.10 in (2.5 mm) centring collar depth matches standard metric servo mounting dimensions. Shaft is 11 mm diameter with a parallel key, 23 mm engagement length — fits standard couplings and pulleys. Maximum radial force on the shaft drops with speed: 710 N at 1000 rpm, 390 N at 6000 rpm. If this motor drives a belt or a direct-mounted pulley, the belt tension must stay below the speed-dependent limit or the front bearing life shortens.
Electrical parameters for drive matching
Stator resistance is 3.84 Ohm and inductance is 12.19 mH — the electrical time constant (L/R) is about 3.2 ms, which sets the current-loop bandwidth ceiling. The torque constant is 0.84 N.m/A at 120 °C copper temperature, and the back EMF constant is 54.08 V/krpm — both needed to calculate the drive's voltage and current requirements at top speed. Maximum continuous current is 9.65 A RMS; the 3-second peak current is also 9.65 A, so the drive's peak-current rating must match or exceed this for acceleration transients. Natural convection cooling means no external fan or air supply — the motor sheds heat through the flange and housing surface.