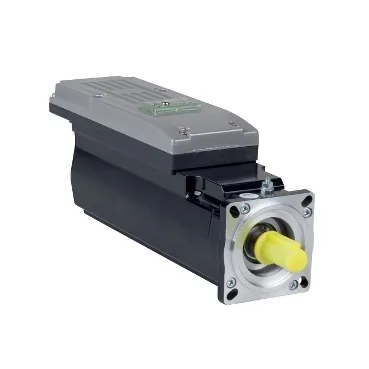
Form factor and shaft geometry
The ILM0703P11F0000 is a Schneider Electric PacDrive 3 series servo motor with integrated drive, built on a 70 mm flange at 11.5 in (293 mm) long with four 5.5 mm mounting holes on a 60 mm centring collar. The output shaft is keyed, 14 mm diameter by 30 mm long with a 20 mm key, and there is no second shaft end — a single-ended shaft simplifies the coupling choice but locks the mounting orientation to the brake side.
Torque, current and power envelope
Continuous stall torque is 2.2 N.m at 3 A, nominal torque is 1.15 N.m, and peak stall torque reaches 8.7 N.m — the 3.95× peak-to-continuous headroom is what the drive commands during accelerations before tripping into the Irms ceiling. Nominal output power is 720 W at a 1.5 A line-rated current, with a 12 A Irms peak, so the upstream servo amplifier sizing is set by the 12 A transient, not the 1.5 A nominal.
Speed, feedback and brake
Position feedback is an absolute single-turn SinCos Hiperface encoder, and the integrated holding brake delivers 3 N.m of static torque — pair the brake as a parking/latch only; the 8.7 N.m peak stall is far above what the brake holds, so the brake is not a dynamic stop.
Thermal and electrical constants
Stator resistance measures 2.7 Ohm phase-to-phase at 20 °C falling to 1.88 Ohm phase-to-neutral at 120 °C; inductance is 13 mH phase-to-phase at 20 °C and 6.5 mH phase-to-neutral at 120 °C — copper drop dominates the I²R loss budget and must be derated against the winding temperature curve, not the ambient. Back-EMF constant is 49 V/krpm at 20 °C and torque constant is 0.76 N.m/A at 120 °C, so a 6000 rpm top speed generates roughly 294 V of BEMF — the drive's DC bus must clear that with margin or the regenerative current clips into the brake circuit.
Shaft loading and environmental ratings
Maximum radial force Fr is derated from 730 N at 1000 rpm down to 400 N at 6000 rpm, with axial force capped at 0.2× Fr — a belt drive on the high-speed end of this curve is the typical fatigue path; couplings that introduce side-load must be re-checked at the operating rpm, not the rated stall. Cooling is natural convection and the sealing is IP54 — this is a cabinet-internal servo, not a washdown or food-grade mounting; any direct splash or oil-mist exposure needs an external shroud or a higher-IP variant from the ILM family.
Sourcing posture
The part ships one per package and is sourced against the BOM quantity, not from a stocked shelf — plan RFQ lead time into the cabinet build rather than treating it as a same-day pull.