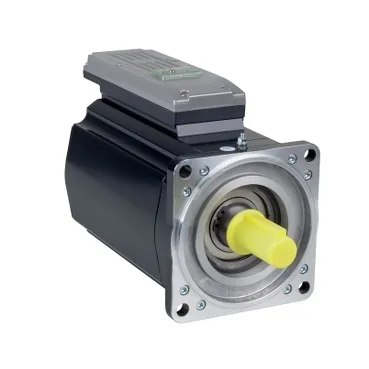
An all-in-one motor/drive with a 140 mm flange footprint
The Schneider Electric ILM1401M21F0000 is a PacDrive 3 series ILM servo motor with an integrated drive stage, built around an international standard flange with a 5.5 in (140 mm) motor flange size and a body length of 11.5 in (292 mm), so it drops into a standard NEMA-style machine mount without adapter plates. Natural convection cooling is the only thermal path on the unit, which keeps the cabinet clean of fans and ducting — but it also means the continuous torque rating assumes the mounting surface acts as a heatsink, and a stuffed enclosure will pull continuous torque down long before it trips the peak figure.
Torque, speed, and what the 1300 W envelope actually means on the line
Continuous stall torque lands at 8.5 N·m with a continuous stall current of 3.2 A and a line-rated current of 3.15 A, while peak stall torque reaches 27 N·m and the drive can deliver a maximum Irms of 14.6 A — that's roughly a 3× overload headroom for short accel/decel bursts on a conveyor index or a small press feed. Nominal torque is 8.3 N·m at the rated 1500 rpm, which lines up with the 1300 W nominal output power — pick a gearbox or pulley ratio off the 8.3 N·m figure for steady-state sizing, and reserve the 27 N·m peak only for short move profiles where duty cycle stays below the thermal ceiling.
Feedback, brake, and shaft detail for the panel-builder
Position feedback is an absolute single-turn SinCos Hiperface encoder, so the controller reads absolute shaft position on power-up with no homing routine — appropriate for indexed motion where losing position after an E-stop would cost a re-home cycle. A holding brake is fitted and rated 18 N·m holding torque, paired with a 24 mm untapped shaft and a 2.0 in (50 mm) shaft length with one keyway at 1.6 in (40 mm) width — there is no second shaft end, so any auxiliary encoder or hand-crank decoupler needs its own bracket. Maximum radial load is 2210 N at 1000 rpm, dropping to 1760 N at 2000 rpm, and maximum axial force is capped at 0.2 × Fr — a belt drive with too much pre-tension will eat the bearings long before the drive ever faults.
Sealing, electrical constants, and what IP65 actually buys you
IP65 sealing on the motor body suits washdown-adjacent areas and most outdoor enclosures, but it is not IP67 — high-pressure hot-water cleaning directly on the unit will eventually defeat the seal. Stator resistance reads 4.58 Ohm phase-to-phase at 20 °C and 3.18 Ohm phase-to-neutral at 120 °C, with stator inductance of 50 mH Ph/Ph at 20 °C and 25 mH Ph/N at 120 °C — these are the values to feed into a torque-loop or field-weakening model, and the temperature coefficient is significant enough that a cold-start tune will drift once the motor warms up.