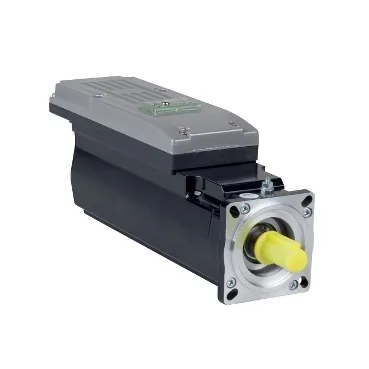
PacDrive 3 ILM, 720 W integrated servo motor
The ILM0702P01A0000 is a Schneider Electric PacDrive 3 series integrated servo motor — the drive electronics sit on the back of the 70 mm flange, so the unit replaces a separate motor-and-drive pair on the machine and shortens the panel-to-machine cable run. Continuous rating is 720 W output at 6000 rpm nominal, with 1.15 N·m nominal torque and 1.5 A line-rated current — the spec pair that decides the matching drive sizing and the heat-soak budget in a sealed cabinet.
Torque envelope — nominal, continuous stall, peak
Three torque points define the working window: 1.15 N·m nominal, 1.7 N·m continuous stall, and 7.6 N·m peak stall — the 6.6:1 peak-to-nominal ratio is the acceleration headroom available during index moves before the I²t trip engages, and it is the figure that matters more than the nominal for short-stroke packaging and pick-and-place sizing. Continuous stall draws 2.5 A and the maximum Irms is 11.8 A — that pair sets the LXM/PacDrive controller sizing and the cable cross-section that survives the peak without nuisance I²T trips on a cold-start index.
Feedback, cooling, and enclosure
Feedback is an absolute single-turn SinCos Hiperface encoder at 128 periods per turn, so absolute position survives a power cycle — the controller comes up knowing axis position without a homing routine on every restart. Cooling is natural convection and the housing is IP54, so the motor is specified for cabinet interiors and clean industrial environments rather than washdown; the holding-brake option is not fitted on this build.
Shaft, flange, and radial load
Output shaft is 11 mm diameter × 23 mm long with an untapped end and no second shaft extension, mounted on a 70 mm international-standard flange with a 60 mm centring collar and four 5.5 mm mounting holes — that is the mating footprint a coupling or gearbox has to match. Maximum radial load Fr scales from 710 N at 1000 rpm down to 390 N at 6000 rpm, and maximum axial Fa is capped at 0.2× Fr — the belt tension or pinion load must be sized against the speed-dependent Fr curve, not a single number on the nameplate.