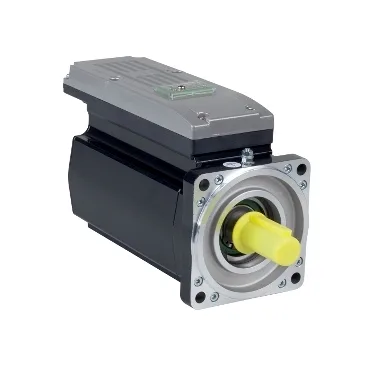
Form factor and mounting — a 100 mm flange servo with integrated drive
The Schneider Electric ILM1001P21F0000 is an ILM-series integrated servo motor from the PacDrive 3 range, meaning the drive electronics live inside the motor housing rather than in a separate cabinet — a single 243 mm-long unit replaces the conventional motor-plus-drive stack and shortens the panel wiring run back to the motion controller. It mounts on a standard 100 mm international flange with four 9 mm mounting holes on a 95 mm centring collar, so it drops into the common motor footprint used across the PacDrive family and pairs with the matching ILM adapter and cable set without a custom bracket. The shaft is 19 mm diameter × 40 mm long, untapped and without a second shaft end, which keeps the coupling choice flexible but means a keyed or clamp-style coupling is required on the driven side.
Torque, speed and electrical envelope — 1.9 N·m nominal with 9.6 N·m peak
Rated 1.9 N·m continuous torque at 3000 rpm nominal speed, with a 9.6 N·m peak stall torque available for acceleration transients — at 1.4 A line current this maps cleanly to the 1.39 N·m/A torque constant at 120 °C winding, so sizing the drive's current loop against a 1.9 N·m load is a straight I = T/Kt calculation rather than a derated estimate. Continuous stall torque is 2.5 N·m at 1.8 A, with the absolute ceiling set by the 7.4 A Irms peak and the stator thermal limit — pushing the motor into the 3000 rpm region at full torque is where natural-convection cooling defines the working envelope, since there is no integrated fan and the heat path is the housing surface only. Stator resistance is 9.8 Ω phase-to-phase at 20 °C (6.82 Ω line-to-neutral at 120 °C) and inductance 45.7 mH at 20 °C — those numbers set the drive's current-loop bandwidth and the bus-cap sizing for dynamic moves, not a nameplate current. The 90 V/krpm back-EMF constant at 20 °C means the drive hits its bus-voltage ceiling at roughly 4000 rpm on a typical 400 V DC link, so the 3000 rpm nominal is the operating sweet spot before field-weakening or voltage headroom comes into play.
Feedback, brake and sealing — SinCos Hiperface absolute, IP65, holding brake fitted
Feedback is a single-turn absolute SinCos Hiperface encoder, which gives the PacDrive 3 controller absolute position on power-up without a homing move and supports the high-resolution commutation needed for low-speed torque ripple control on packaging and converting lines. The motor ships with an integral holding brake rated 5.5 N·m holding torque — that figure matches or exceeds the 1.9 N·m nominal torque, so the brake holds the load safely at standstill and during E-stop; expect the brake to add roughly the rotor inertia and a small axial extension on the rear face. IP65 sealing at the shaft and body means the unit tolerates washdown and dust-laden environments typical of food-and-bev, pharma and general factory floors — the rating applies to the motor body, not the mating connector, so the cordset still needs its own sealed spec to keep the system at IP65.
Shaft loads and rotor — what the bearings actually see
Maximum radial load is 900 N at 1000 rpm, dropping to 720 N at 2000 rpm and 630 N at 3000 rpm — the fall-off follows the standard belt-drive or pinion loading curve, so when the application runs near top speed a smaller pulley or a direct-coupled gearbox is the way to keep the radial force inside the envelope. Axial load is limited to 0.2 × Fr, which is the usual proportion for a preloaded deep-groove bearing pair — a timing-belt drive with modest side load is fine, but a thrust-bearing-mounted lead screw or a heavy overhung pinion will push the axle force outside the spec.
Sourcing posture for ILM1001P21F0000
The lifecycle record carries a current status flag, so this code is treated as an in-production part on the manufacturer's range, not a discontinued or NRND line — that means the replacement risk on a new machine build is low, but stocking strategy for spares should still assume long-horizon availability rather than immediate shelf stock. As a PacDrive 3 ILM with an integrated drive, this unit is sourced through independent distribution and quoted against the BOM quantity at RFQ; lead time and volume breaks are confirmed at quote time rather than read off a price sheet. For maintenance spares, match the original PacDrive 3 ILM configuration on the nameplate — feedback code, brake option, flange and shaft detail — before specifying, since the Hiperface single-turn encoder and the integrated-drive architecture are the load-bearing choices that change with a different code.