Performance envelope — torque, speed, and power
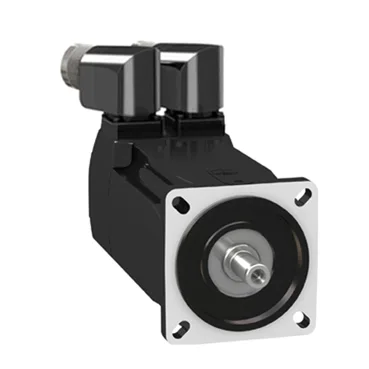
The MH30702P07F2200: Rated for 1380 W continuous output power at a nominal speed of 5500 rpm, this motor delivers a nominal torque of 2.37 N.m (20.98 lbf.in) when paired with an LXM52 drive at 115 V three-phase supply. The torque constant of 0.84 N.m/A and back EMF constant of 54.08 V/krpm define the drive tuning parameters — the drive's current loop must be set to match these values for stable torque control across the speed range. Peak stall torque reaches 7.4 N.m (65.5 lbf.in) across the 115...480 V three-phase range, giving a 3:1 overload margin over the continuous stall torque of 2.48 N.m. This headroom handles short-duration acceleration or load transients without tripping the drive. The maximum continuous current Irms is 9.65 A — the drive's rated output current must equal or exceed this figure to deliver full torque at rated speed. The 3-second peak current is also 9.65 A, so the overload capability is limited by the motor thermal time constant, not the current ceiling.
Encoder and feedback — absolute position retention
Equipped with a Multiturn SinCos Hiperface encoder, this motor provides absolute position feedback over multiple shaft revolutions. The SinCos analog tracks support high-resolution velocity and position loops, while the Hiperface digital interface carries the multiturn count — the drive retains the absolute position after a power cycle without needing a homing routine.
Holding brake — vertical load security
The integrated holding brake delivers 3 N.m (26.6 lbf.in) of holding torque, sufficient to secure a vertical-axis load when the drive is disabled. Brake pull-in power is 7 W — the drive's brake control output must supply this at the rated voltage, and the brake release time should be accounted for in the motion sequence to avoid dragging the load before the brake fully opens.
Mounting and environmental sealing
The motor flange size is 70 mm (2.8 in) with a centring collar diameter of 60 mm and a centring collar depth of 2.5 mm — this matches the standard IEC mounting pattern for servo motors in this power class. Four mounting holes of 5.5 mm diameter accept M5 bolts; the pilot diameter centres the motor on the machine frame. IP65 protection means the motor housing is dust-tight and protected against water jets from any direction. The rotatable right-angled connectors allow the cable exit to be oriented in 90° increments, simplifying cable routing in tight enclosures. Natural convection cooling requires unobstructed airflow around the frame — no fan is fitted, so derating applies if the motor is enclosed or mounted in a confined space. The maximum radial force at the shaft is 710 N at 1000 rpm, derating to 390 N at 6000 rpm. For belt-driven or direct-coupled loads, the applied radial load must stay below the curve at the operating speed to avoid bearing fatigue.