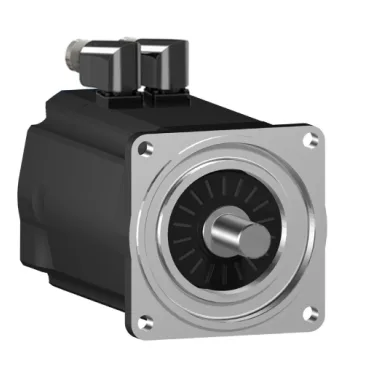
Power stage and speed range by supply voltage
The SH31404P02F2100 is a three-phase servo motor whose nominal speed depends on the supply: 3000 rpm at 400 V three-phase is the target for most industrial lines, while 3600 rpm is available at 480 V three-phase, and lower speeds of 750 rpm or 1500 rpm on single-phase supplies (115 V or 230 V respectively). Continuous power at 400 V three-phase is 4040 W — this is the thermal rating for sizing the drive and the motor cable; the motor also delivers 4190 W at 480 V three-phase and 4130 W at 230 V single-phase. The continuous stall torque is 33.4 N.m across the 115...480 V three-phase range, meaning the motor can hold that torque indefinitely at zero speed without exceeding the 130 °C copper hot winding temperature.
Encoder, brake, and mechanical interface — what to expect on the machine side
The absolute multiturn SinCos Hiperface encoder retains position through a power cycle — no homing sequence is needed on restart, which simplifies commissioning on multi-axis lines where a reference run would waste cycle time. A holding brake is integrated, rated at 36 N.m static holding torque. This brake holds the load at zero speed with motor windings unpowered; it is not rated for dynamic stopping — the drive decelerates the load, and the brake locks after standstill. The shaft is smooth (no keyway), 24 mm diameter by 50 mm long, so the load coupling must use a clamping or friction-fit method. The motor mounts via an international standard flange with a 140 mm flange size, a 130 mm centring collar diameter, and 11 mm mounting holes. The electrical connection is a rotatable right-angled connector — the cable exit orientation can be adjusted in 90° increments to suit the cable routing in the cabinet or along the machine frame, which is useful in tight enclosures.
Torque, current, and thermal limits for drive sizing
Nominal torque at 400 V three-phase is 12.9 N.m. For acceleration or overcoming friction peaks, the peak stall torque is 131.9 N.m, available for short durations — the drive must be sized to supply the corresponding maximum current of 95.6 A Irms. The torque constant is 1.57 N.m/A at 120 °C copper hot — this is the ratio for converting drive current to motor torque in the hot winding condition; the cold torque constant will be slightly higher. The back EMF constant is 104 V/krpm at 20 °C, which sets the voltage-speed limit — above rated speed the drive must enter field-weakening mode. Stator inductance is 2.035 mH and stator resistance is 0.28 Ohm — these values feed the drive's current regulator tuning and the thermal model for I²t protection. The motor has 5 poles, so the electrical frequency at 3000 rpm is 125 Hz (ns = 120 × f / p). Cooling is by natural convection — no external fan; the motor relies on its surface area and the mounting flange for heat dissipation. The IP65 rating on both the motor body and the shaft bushing means it withstands washdown environments (conforming to IEC 60034-5), suitable for food-and-bev or wet machining lines.
Load limits: axial and radial force constraints
The maximum axial force on the shaft is 300 N — the load must not push or pull axially beyond this limit, or the bearing life is compromised. The maximum radial force is speed-dependent: 2660 N at 1000 rpm, derating to 2110 N at 2000 rpm and 1840 N at 3000 rpm.
The sizing reference SH31404P identifies the motor frame and winding family; the full order code specifies the brake, encoder, connector, and shaft options.