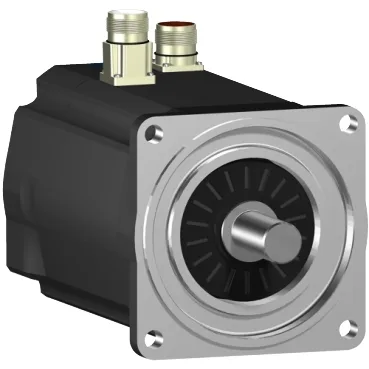
4040 W continuous, 131.9 Nm peak — the torque envelope that defines the machine cycle
The SH31404P11A1200 delivers 4040 W continuous power at 400 V three-phase, with a nominal torque of 30.2 Nm and a peak stall torque of 131.9 Nm across the 115...480 V three-phase range. That peak figure — over 4× the continuous rating — is the number that governs acceleration and emergency stop profiles on a pick-and-place or rotary indexing station. Speed follows the supply: 3000 rpm at 400 V three-phase, 3600 rpm at 480 V three-phase, and 750/1500 rpm on single-phase 115/230 V respectively. The motor is wound for the higher voltage range; single-phase operation derates both torque and speed.
Absolute single-turn SinCos Hiperface encoder — position at power-on, no homing cycle
The encoder is an absolute single-turn SinCos Hiperface type. Single-turn means it tracks position within one revolution (typically 4096 or 65536 counts per turn depending on the resolution variant) and retains that value when power is removed. No homing sequence on restart — the axis knows where it is the instant the drive powers up, which saves a few seconds per cycle on multi-axis machines. SinCos analog tracks (1 Vpp sine/cosine) give the drive fine interpolation beyond the digital resolution, while the Hiperface protocol carries the absolute position data. The drive must support Hiperface interface — check compatibility with the intended servo drive model before wiring.
IP65 motor body, IP67 housing — washdown-ready without a cover
The motor body and shaft bushing meet IP65 per IEC 60034-5, and the housing meets IP67. That means the winding and bearings are protected against dust ingress and low-pressure water jets (IP65), and the housing can survive brief immersion (IP67). Suitable for food-and-bev washdown zones or outdoor conveyor sections where hose-down cleaning is routine. Natural convection cooling (no external fan) means no moving parts to ingest debris, but the thermal budget is set by the motor surface area and the ambient. In a confined cabinet or high-ambient environment, derate the continuous torque or add forced air across the housing.
Electrical parameters for the drive tuning engineer
Stator resistance is 0.28 Ohm, stator inductance 2.035 mH — these set the electrical time constant (L/R ≈ 7.3 ms) that the current loop must handle. The torque constant is 1.57 Nm/A at 120 °C copper temperature; the back EMF constant is 104 V/krpm at 20 °C. Both are temperature-sensitive: expect the torque constant to drop and the back EMF to rise as the motor warms to its 130 °C rated hot-spot temperature. Maximum RMS current is 95.6 A, with a 3-second peak of the same value — the peak current limit is set by the drive's output capability, not the motor's thermal limit. Use the drive's current-loop bandwidth to stay within the motor's demagnetisation curve; the datasheet's peak stall torque figure assumes the drive can deliver that current at the correct phase angle.
Mounting dimensions and mechanical interface
Motor flange size is 140 mm (5.5 in) with a centring collar diameter of 130 mm (5.1 in) and a centring collar depth of 3.5 mm (0.1 in). Mounting holes are 11 mm diameter on the flange bolt circle — standard for this frame size. The shaft is 24 mm diameter with a parallel key, key width 8 mm, shaft length 50 mm.